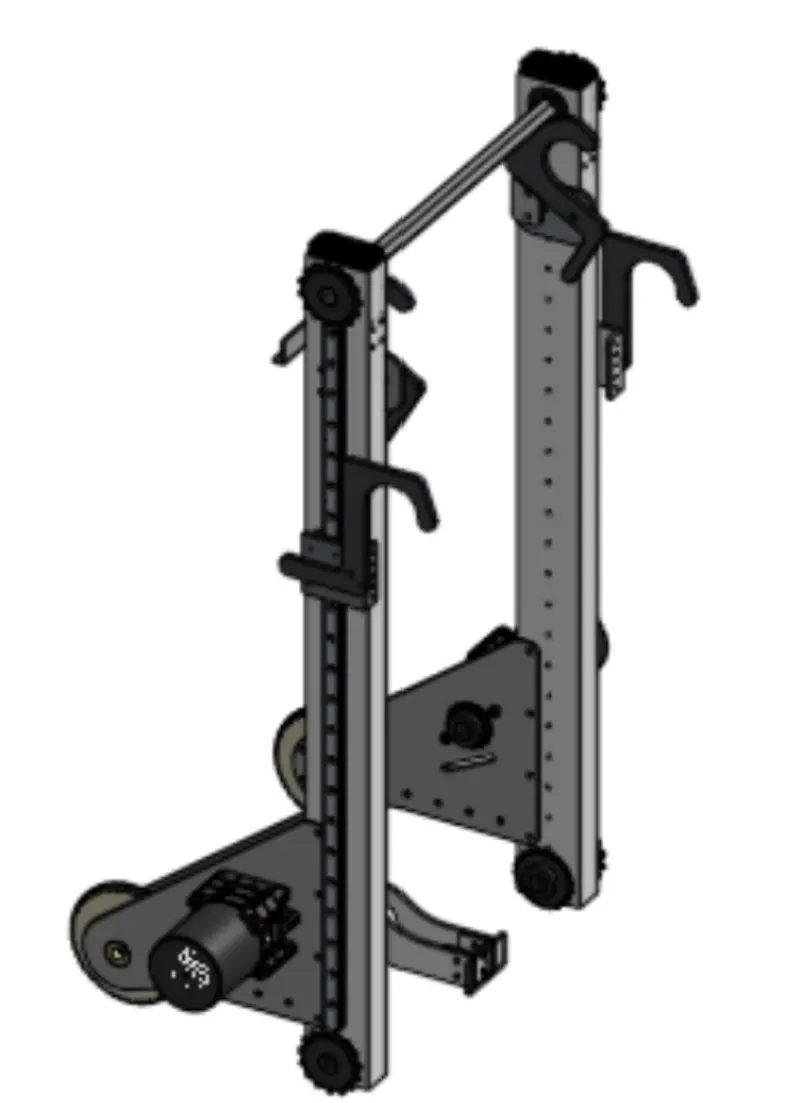
Deployable Multi-Level Climbing Mechanism
A deployable climber that carries the full weight of the robot up multiple bars on alternating carbon-fiber hooks — packaged into three inches of space between the swerve modules and shooter.
I design, manufacture, test, and iterate mechanical systems for robotics and real hardware.
A deployable climber that carries the full weight of the robot up multiple bars on alternating carbon-fiber hooks — packaged into three inches of space between the swerve modules and shooter.
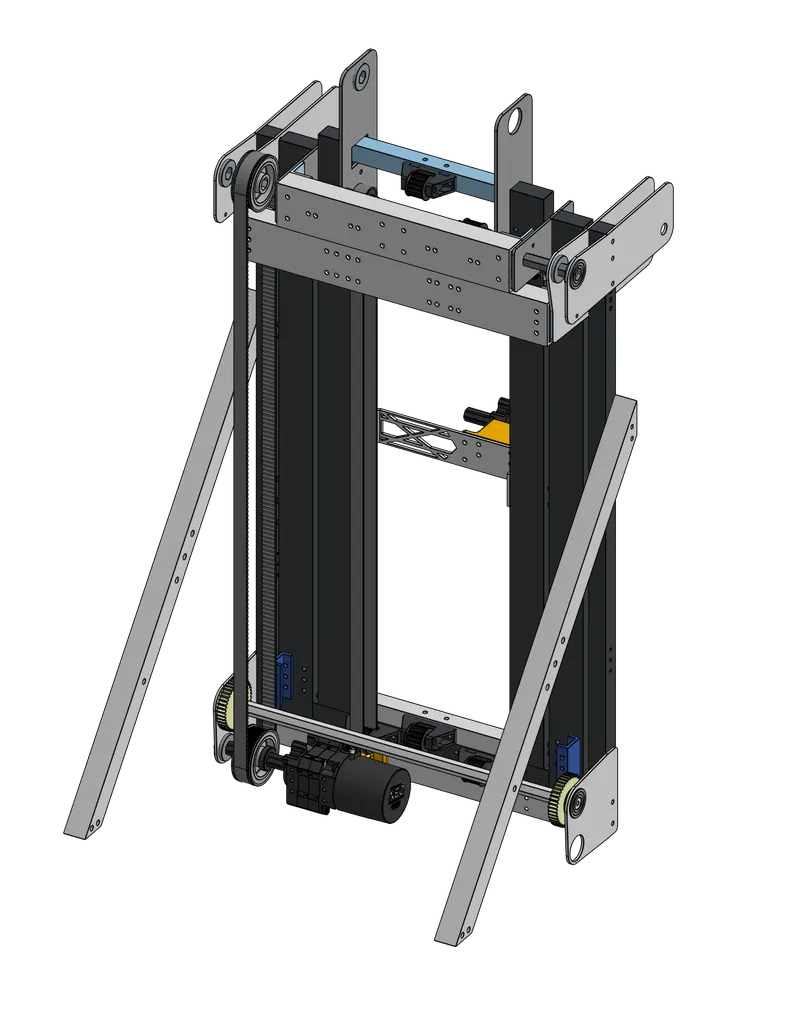
A fully belt-driven three-stage cascading elevator that reaches a 7-ft scoring target from inside a 3 ft 6 in. starting-height envelope — redesigned component-by-component through testing.
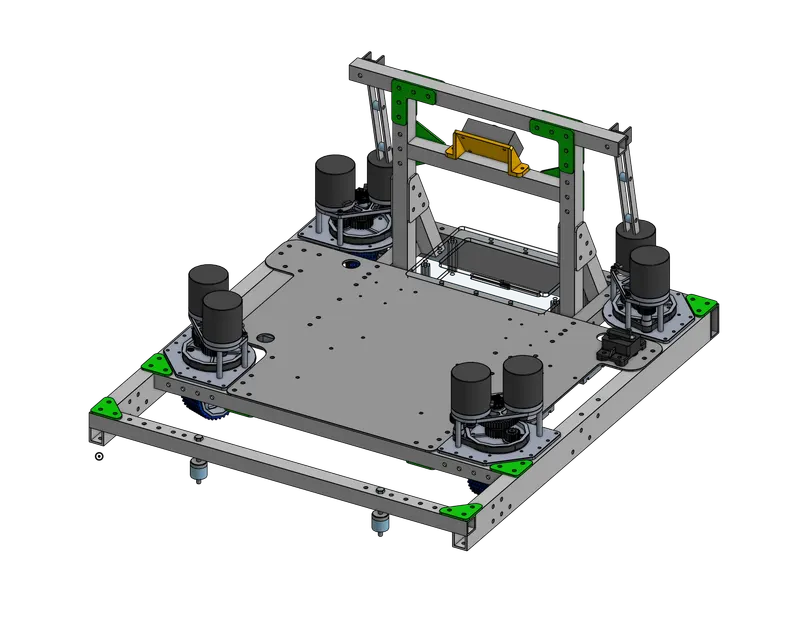
The complete mechanical architecture for a 2024 FRC robot — chassis, frame rails, bellypan, and an under-bellypan electronics layout that freed the upper chassis for the elevator, climber, and under-bumper intake.
A group-built 5-inch FPV drone combining mechanical assembly, electrical integration, configuration, and flight testing. A separate group case study is in progress.
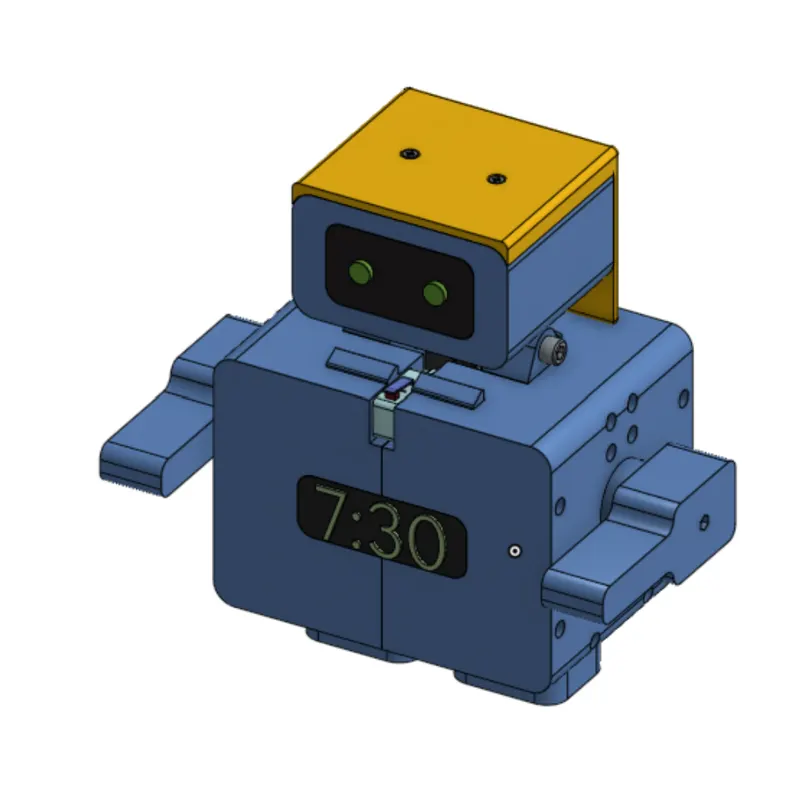
A character-driven mechanical alarm clock whose spring-return head, passive latch, servo linkage, articulated controls, and OLED turn the alarm sequence into a physical interaction.
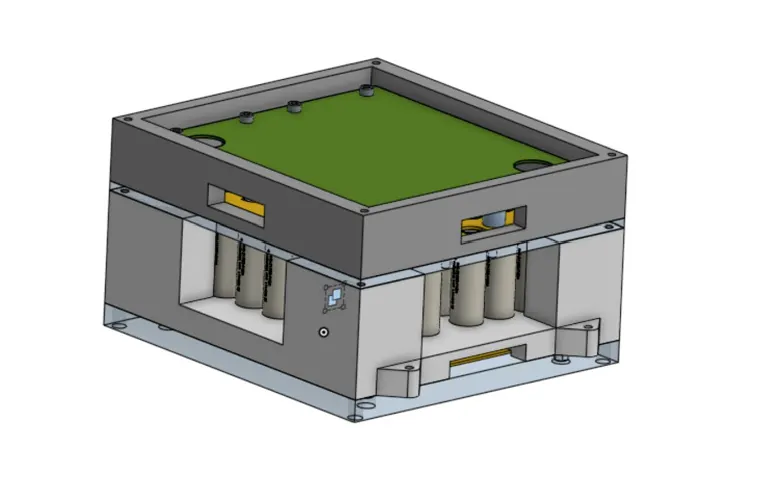
Designed and analyzed a 42-cell 14S3P battery module in SolidWorks, focusing on structural integrity, cell spacing, insulation, battery-system integration, and manufacturability.
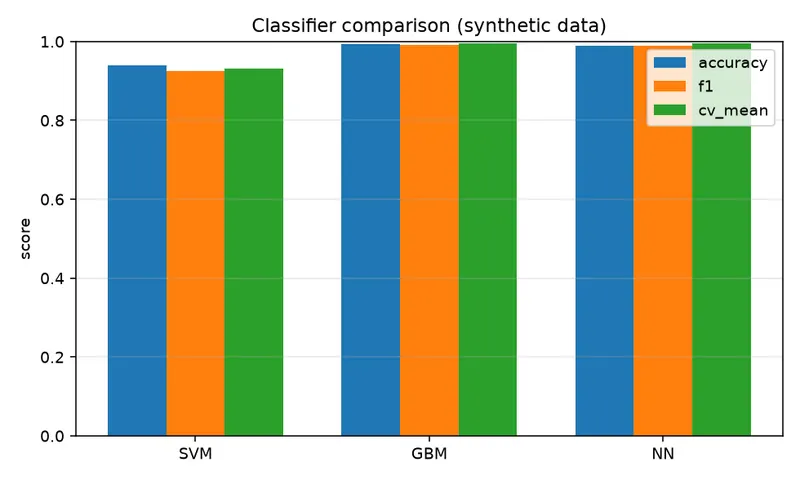
A two-person research project on wearable cardiovascular signals — I built the SwiftUI iOS application and HealthKit data collection, and drove the app concept and system architecture around a machine-learning study.
Led a 40-member team across robot development, mechanical design, manufacturing, technical training, outreach, and STEM fundraising.
Led social media and used Stable Diffusion, video editing, and four AI outreach systems in work associated with ~$200K lifetime revenue.
Created Python and Scratch curriculum, taught online and in person, and supported 40+ signups and ~$28K revenue.
Founded Feeding Hope, raised ~$20K for visually challenged students, supported ~$50K through UTSAV, and mentored FLL students.
I'm a mechanical engineering student at the University of California, Berkeley. Most of my engineering experience comes from four years of FIRST Robotics Competition, where I led a 40-member team and designed the mechanisms, drivetrain architecture, and robot packaging that had to survive real matches.
My work sits where mechanical design meets manufacturing and testing: CAD in Onshape and SolidWorks, CNC and manual machining, plasma cutting, 3D printing, and the iteration cycle that follows the first time a part breaks.